International Baccalaureate · DP 2: Applications and Interpretation HL
Affine Transformations
I
Linear Transformations
I.1
Matrix Products and Determinants
Recappreviously studied — click to reread
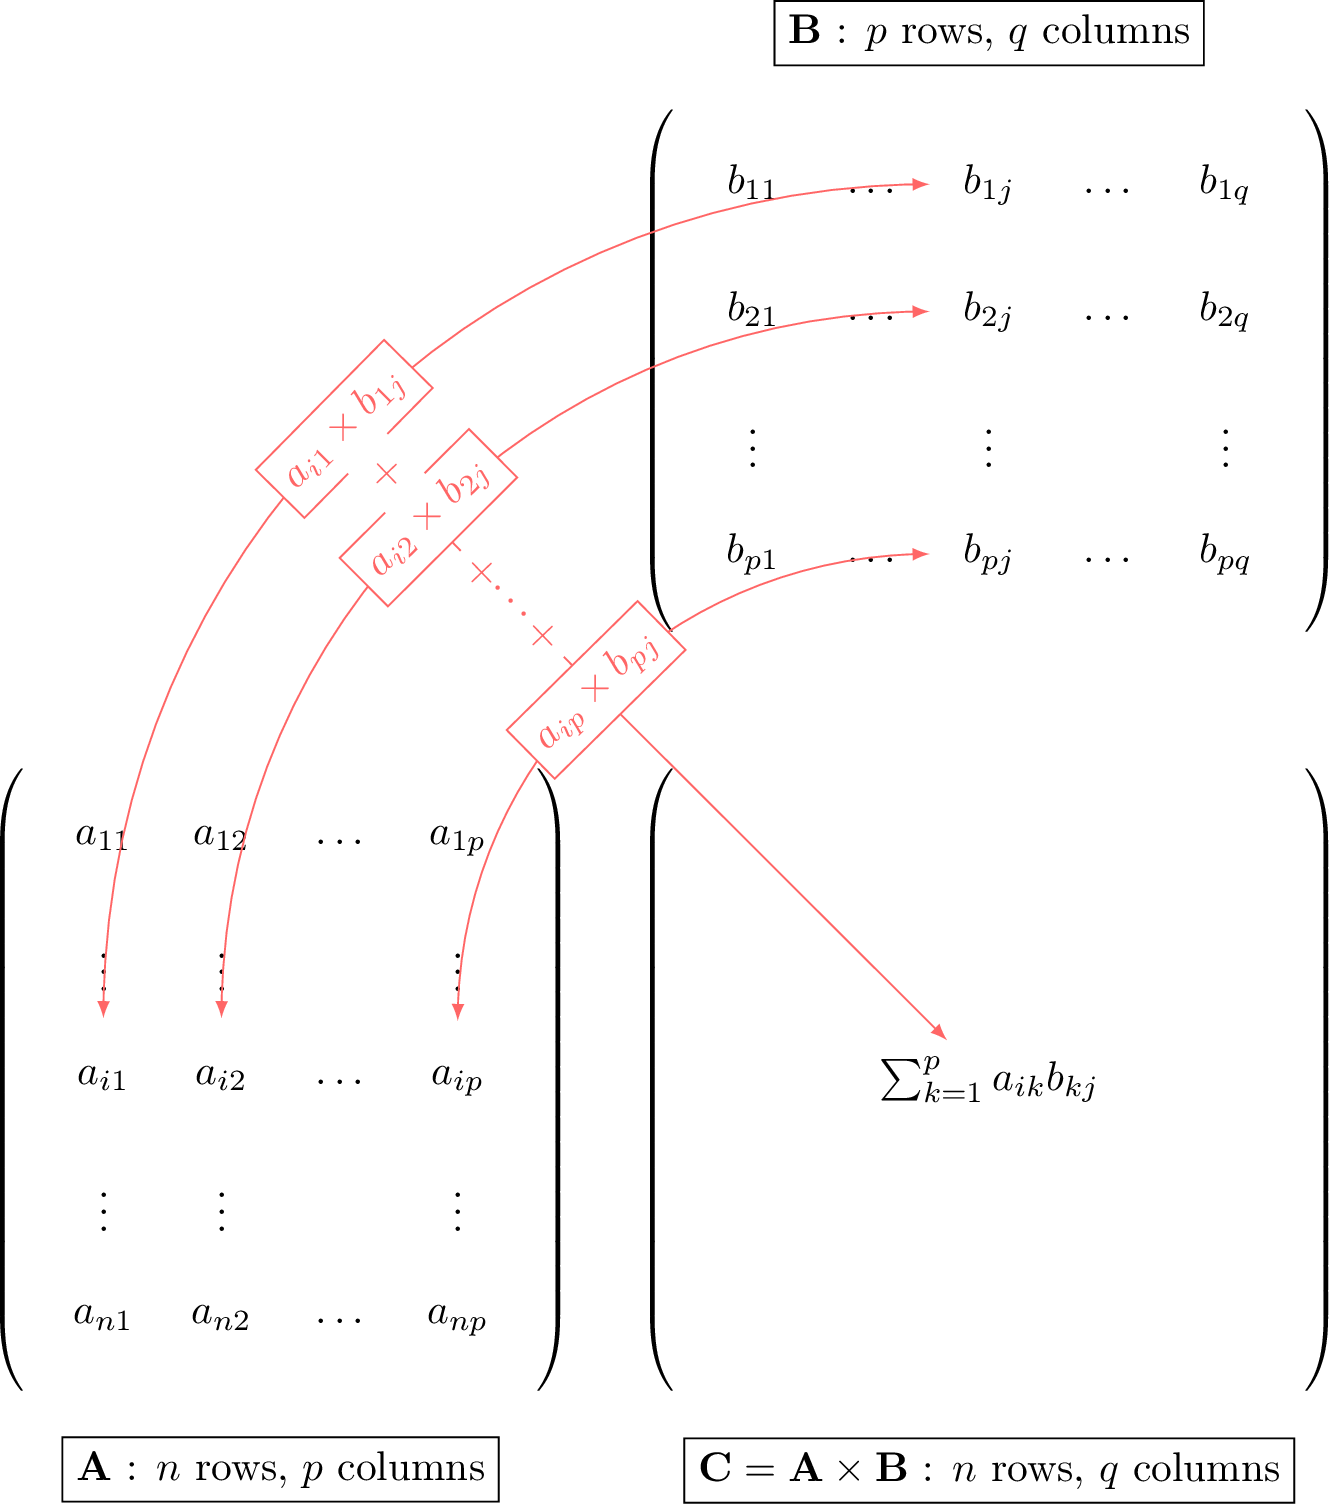
Definition — Matrix Multiplication
Let \(\mathbf{A}\) be a matrix of size \(n\times p\) and \(\mathbf{B}\) be a matrix of size \(p\times q\).The matrix product \(\mathbf{A}\times \mathbf{B}\) is a matrix \(\mathbf{C}\) of size \(n\times q\) where the entry \(c_{ij}\) is the dot product of the \(i\)-th row of \(\mathbf{A}\) and the \(j\)-th column of \(\mathbf{B}\): $$ c_{ij}=\sum_{k=1}^p a_{ik}b_{kj}, \qquad 1 \leq i \leq n,\; 1 \leq j \leq q. $$
Definition — Determinant of a 2x2 Matrix
Let \(\mathbf{A} = \begin{pmatrix} a & b \\ c & d \end{pmatrix}\) be a square matrix of order \(2\).The determinant of \(\mathbf{A}\) is \(ad-bc\). It is denoted \(\det(\mathbf{A})\).
Skills to practice
- Matrix Products and Determinants
I.2
Linear Transformations of the Plane
Affine transformations are fundamental geometric operations that map points to points and, when their linear part is invertible, lines to lines and planes to planes while preserving parallelism (a degenerate transformation can collapse a line to a point). They are widely used in computer graphics, physics, and robotics to describe movements and deformations. An affine transformation combines a linear transformation (such as rotation, scaling, or reflection) with a translation. Matrices can represent and perform these transformations efficiently in 2D space.
We consider how an object point \((x, y)\), specified by its vector position \(\mathbf{x} = \begin{pmatrix} x \\ y \end{pmatrix}\), is moved to an image point \((x', y')\), specified by its vector position \(\mathbf{x}' = \begin{pmatrix} x' \\ y' \end{pmatrix}\), using matrices.
We consider how an object point \((x, y)\), specified by its vector position \(\mathbf{x} = \begin{pmatrix} x \\ y \end{pmatrix}\), is moved to an image point \((x', y')\), specified by its vector position \(\mathbf{x}' = \begin{pmatrix} x' \\ y' \end{pmatrix}\), using matrices.
Definition — Linear Transformation of the Plane
The plane is given an orthonormal coordinate system. A transformation \(T\) of the plane is called linear if it maps a point \(P(x, y)\) to an image point \(P'(x', y')\) such that the coordinates satisfy a system of linear equations, where \(a\), \(b\), \(c\), \(d\) are fixed real numbers:$$\begin{cases}x' = ax + by \\
y' = cx + dy\end{cases}$$ This can be written in matrix form as:$$\begin{pmatrix} x' \\
y' \end{pmatrix} = \mathbf{A} \begin{pmatrix} x \\
y \end{pmatrix} \quad \text{where} \quad \mathbf{A} = \begin{pmatrix} a & b \\
c & d \end{pmatrix}.$$ The matrix \(\mathbf{A}\) is called the transformation matrix.
In what follows, we identify a point \(P(x, y)\) with its position vector \(\mathbf{x} = \begin{pmatrix} x \\ y \end{pmatrix}\): the matrix \(\mathbf{A}\) acts on points through their position vectors. A key property of linear transformations is that the origin is mapped to itself: \(T(0,0) = (0,0)\). Furthermore, the columns of the matrix \(\mathbf{A}\) reveal where the basis vectors \(\vec{i}=\begin{pmatrix} 1 \\ 0 \end{pmatrix}\) and \(\vec{j}=\begin{pmatrix} 0 \\ 1 \end{pmatrix}\) land.$$ \mathbf{A}\begin{pmatrix} 1 \\
0 \end{pmatrix} = \begin{pmatrix} a \\
c \end{pmatrix} \quad \text{and} \quad \mathbf{A}\begin{pmatrix} 0 \\
1 \end{pmatrix} = \begin{pmatrix} b \\
d \end{pmatrix}. $$ This means the first column is the image of \(\vec{i}\) and the second column is the image of \(\vec{j}\).
Example
Find the image of the point \(P(2, 3)\) under the transformation defined by the matrix \(\mathbf{A} = \begin{pmatrix} 2 & 0 \\ 0 & 3 \end{pmatrix}\).
$$\begin{aligned}\begin{pmatrix} x' \\
y' \end{pmatrix} &= \begin{pmatrix} 2 & 0 \\
0 & 3 \end{pmatrix} \begin{pmatrix} 2 \\
3 \end{pmatrix}\\
&= \begin{pmatrix} 2(2) + 0(3) \\
0(2) + 3(3) \end{pmatrix}\\
&= \begin{pmatrix} 4 \\
9 \end{pmatrix} \end{aligned}$$ The image is \(P'(4, 9)\). This transformation represents a horizontal stretch by factor 2 and a vertical stretch by factor 3.
Skills to practice
- Applying Linear Transformations
I.3
Standard Linear Transformations
Definition — Scaling/Enlargement
- A horizontal stretch (or stretch parallel to the \(x\)-axis) with scale factor \(k\) is represented by:$$ \mathbf{S}_x = \begin{pmatrix} k & 0 \\ 0 & 1 \end{pmatrix} $$
- A vertical stretch (or stretch parallel to the y-axis) with scale factor \(k\) is represented by:$$ \mathbf{S}_y = \begin{pmatrix} 1 & 0 \\ 0 & k \end{pmatrix} $$
- An enlargement (or scaling) centered at the origin with horizontal scale factor \(k\) and vertical scale factor \(m\) is represented by:$$ \mathbf{S} = \begin{pmatrix} k & 0 \\ 0 & m \end{pmatrix} $$ If \(k=m\), it is a uniform enlargement (homothety) with scale factor \(k\) — a reduction when \(k < 1\). These definitions take \(k, m > 0\): a negative factor combines the stretch with a reflection.
Example
Find the image of the position vector \(\begin{pmatrix} 2 \\ 3 \end{pmatrix}\) under the horizontal stretch of scale factor \(3\).
The matrix for a horizontal stretch with factor \(k=3\) is \(\mathbf{S} = \begin{pmatrix} 3 & 0 \\ 0 & 1 \end{pmatrix}\).$$\begin{aligned}\mathbf{x}' &= \mathbf{S}\mathbf{x} \\
&= \begin{pmatrix} 3 & 0 \\
0 & 1 \end{pmatrix} \begin{pmatrix} 2 \\
3 \end{pmatrix} \\
&= \begin{pmatrix} 3(2) + 0(3) \\
0(2) + 1(3) \end{pmatrix} \\
&= \begin{pmatrix} 6 \\
3 \end{pmatrix}\end{aligned}$$ 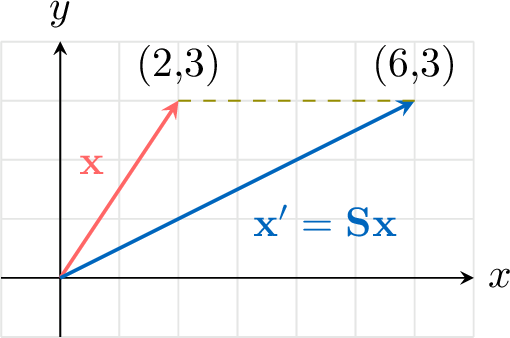
Definition — Reflection
- Reflection in the \(x\)-axis: \((x, y) \to (x, -y)\) $$ \mathbf{M}_x = \begin{pmatrix} 1 & 0 \\ 0 & -1 \end{pmatrix} $$
- Reflection in the \(y\)-axis: \((x, y) \to (-x, y)\) $$ \mathbf{M}_y = \begin{pmatrix} -1 & 0 \\ 0 & 1 \end{pmatrix} $$
- Reflection in the line \(y=x\): \((x, y) \to (y, x)\) $$ \mathbf{M}_{y=x} = \begin{pmatrix} 0 & 1 \\ 1 & 0 \end{pmatrix} $$
- Reflection in the line \(y=(\tan\theta)x\) (for \(\theta \neq 90^\circ\); the \(y\)-axis is the case \(\theta = 90^\circ\) of the matrix formula):$$\mathbf{M}_{y=(\tan\theta)x}=\begin{pmatrix}\cos(2\theta) & \sin(2\theta)\\ \sin(2\theta) & -\cos(2\theta)\end{pmatrix}.$$
We derive the matrix of the reflection in the line through the origin at angle \(\theta\) to the \(x\)-axis; for \(\theta \neq 90^\circ\) this is the line \(y = (\tan\theta)x\). The values \(\theta = 0\) and \(\theta = 45^\circ\) recover \(\mathbf{M}_x\) and \(\mathbf{M}_{y=x}\); the \(y\)-axis is the case \(\theta = 90^\circ\), covered by the matrix formula (\(2\theta = 180^\circ\)) even though the description \(y = (\tan\theta)x\) fails there. A unit vector at angle \(\varphi\) reflects, across the line at angle \(\theta\), to the unit vector at angle \(2\theta - \varphi\) (the line bisects the angle between a vector and its image). Hence $$\mathbf{e_1} \mapsto \begin{pmatrix} \cos 2\theta \\
\sin 2\theta \end{pmatrix} \qquad\text{and}\qquad \mathbf{e_2} \mapsto \begin{pmatrix} \cos(2\theta - 90^\circ) \\
\sin(2\theta - 90^\circ) \end{pmatrix} = \begin{pmatrix} \sin 2\theta \\
-\cos 2\theta \end{pmatrix}.$$ Placing these images as columns gives \(\begin{pmatrix} \cos 2\theta & \sin 2\theta \\ \sin 2\theta & -\cos 2\theta \end{pmatrix}\).
Example
Find the image of the position vector \(\begin{pmatrix} 2 \\ 3 \end{pmatrix}\) under reflection in the \(x\)-axis.
The matrix for reflection in the \(x\)-axis is \(\mathbf{M}_x = \begin{pmatrix} 1 & 0 \\ 0 & -1 \end{pmatrix}\).$$\begin{aligned}\mathbf{x}' &= \mathbf{M}_x\mathbf{x} \\
&= \begin{pmatrix} 1 & 0 \\
0 & -1 \end{pmatrix} \begin{pmatrix} 2 \\
3 \end{pmatrix} \\
&= \begin{pmatrix} 1(2) + 0(3) \\
0(2) + (-1)(3) \end{pmatrix} \\
&= \begin{pmatrix} 2 \\
-3 \end{pmatrix}\end{aligned}$$ 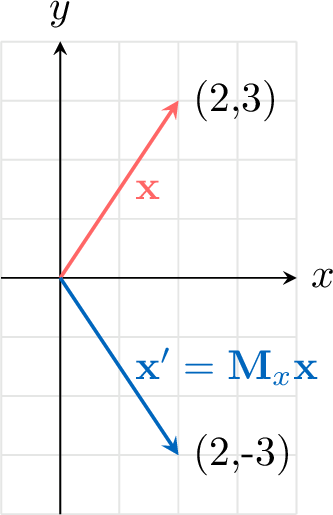
Definition — Rotation
A rotation of angle \(\theta\) anti-clockwise about the origin is represented by:$$ \mathbf{R}_{\theta} = \begin{pmatrix} \cos \theta & -\sin \theta \\
\sin \theta & \cos \theta \end{pmatrix} $$
The matrix of a linear transformation has as columns the images of the basis vectors \(\mathbf{e_1} = \begin{pmatrix} 1 \\ 0 \end{pmatrix}\) and \(\mathbf{e_2} = \begin{pmatrix} 0 \\ 1 \end{pmatrix}\). Under the rotation of angle \(\theta\) about the origin, the unit vector \(\mathbf{e_1}\), at angle \(0\), is sent to the unit vector at angle \(\theta\): $$\mathbf{e_1} \mapsto \begin{pmatrix} \cos\theta \\
\sin\theta \end{pmatrix};$$ the unit vector \(\mathbf{e_2}\), at angle \(90^\circ\), is sent to the unit vector at angle \(\theta + 90^\circ\): $$\mathbf{e_2} \mapsto \begin{pmatrix} \cos(\theta + 90^\circ) \\
\sin(\theta + 90^\circ) \end{pmatrix} = \begin{pmatrix} -\sin\theta \\
\cos\theta \end{pmatrix}.$$ Placing these two images as columns gives \(\mathbf{R}_{\theta} = \begin{pmatrix} \cos\theta & -\sin\theta \\ \sin\theta & \cos\theta \end{pmatrix}\).
Culture: identifying the point \((x, y)\) with the complex number \(x + iy\), the rotation of angle \(\theta\) is the multiplication by \(e^{i\theta} = \cos\theta + i\sin\theta\) — the two viewpoints give the same matrix.
Example
Find the image of the position vector \(\begin{pmatrix} 2 \\ 3 \end{pmatrix}\) under a rotation of \(90^\circ\) (\(\frac{\pi}{2}\) radians) anti-clockwise.
The matrix for rotation of \(90^\circ\) is \(\mathbf{R}_{90^\circ} = \begin{pmatrix} \cos 90^\circ & -\sin 90^\circ \\ \sin 90^\circ & \cos 90^\circ \end{pmatrix} = \begin{pmatrix} 0 & -1 \\ 1 & 0 \end{pmatrix}\).$$\begin{aligned}\mathbf{x}' &= \mathbf{R}_{90^\circ} \mathbf{x} \\
&= \begin{pmatrix} 0 & -1 \\
1 & 0 \end{pmatrix} \begin{pmatrix} 2 \\
3 \end{pmatrix} \\
&= \begin{pmatrix} 0(2) + (-1)(3) \\
1(2) + 0(3) \end{pmatrix} \\
&= \begin{pmatrix} -3 \\
2 \end{pmatrix}\end{aligned}$$ 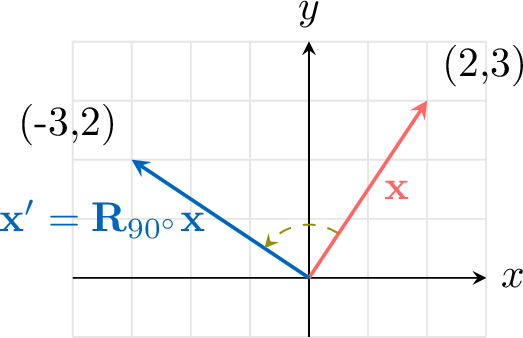
Clockwise Rotation
A rotation through \(\theta\) clockwise about the origin is the rotation through \(-\theta\) anti-clockwise. Since \(\cos(-\theta) = \cos\theta\) and \(\sin(-\theta) = -\sin\theta\), its matrix is $$\begin{aligned}[t] \mathbf{R}_{-\theta} &= \begin{pmatrix} \cos(-\theta) & -\sin(-\theta) \\
\sin(-\theta) & \cos(-\theta) \end{pmatrix} && \text{(rotation through } -\theta\text{)} \\
&= \begin{pmatrix} \cos\theta & \sin\theta \\
-\sin\theta & \cos\theta \end{pmatrix}. \end{aligned}$$
Example
Find the matrix of the rotation through \(\frac{\pi}{6}\) (\(30^\circ\)) clockwise about the origin, then the image of the point \(P(2, 0)\).
A clockwise rotation through \(\frac{\pi}{6}\) is the rotation through \(-\frac{\pi}{6}\): $$\begin{aligned}[t] \mathbf{R}_{-\frac{\pi}{6}} &= \begin{pmatrix} \cos\frac{\pi}{6} & \sin\frac{\pi}{6} \\
-\sin\frac{\pi}{6} & \cos\frac{\pi}{6} \end{pmatrix} && \text{(clockwise rotation matrix)} \\
&= \begin{pmatrix} \frac{\sqrt{3}}{2} & \frac{1}{2} \\
-\frac{1}{2} & \frac{\sqrt{3}}{2} \end{pmatrix}. \end{aligned}$$ The image of \(P\): $$\begin{aligned}[t] \mathbf{x}' &= \begin{pmatrix} \frac{\sqrt{3}}{2} & \frac{1}{2} \\
-\frac{1}{2} & \frac{\sqrt{3}}{2} \end{pmatrix} \begin{pmatrix} 2 \\
0 \end{pmatrix} \\
&= \begin{pmatrix} \frac{\sqrt{3}}{2}(2) + \frac{1}{2}(0) \\
-\frac{1}{2}(2) + \frac{\sqrt{3}}{2}(0) \end{pmatrix} \\
&= \begin{pmatrix} \sqrt{3} \\
-1 \end{pmatrix}. \end{aligned}$$ The image is \(P'(\sqrt{3}, -1)\), below the \(x\)-axis: the point has turned clockwise. Check: \(OP' = \sqrt{3 + 1} = 2 = OP\). 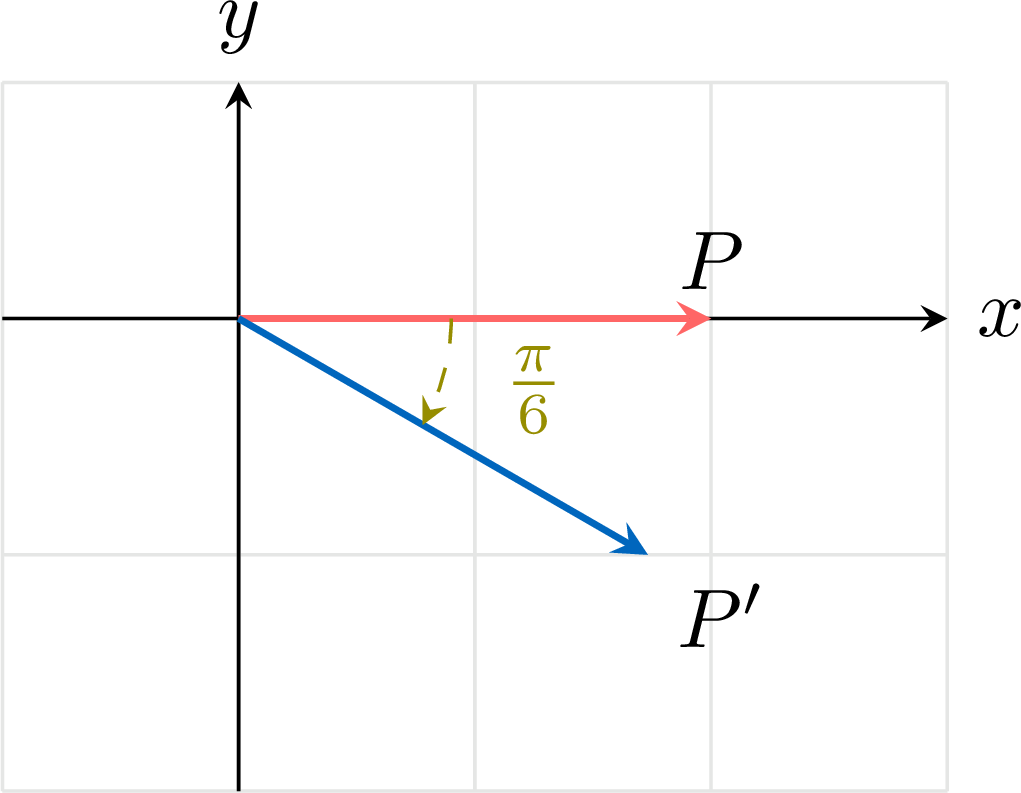
Skills to practice
- Recognising Transformation Matrices
- Finding the Matrix Representation
- Applying Standard Linear Transformations
- Identifying the Transformation
II
Translations and Affine Transformations
II.1
Translation
Definition — Translation
A translation by vector \(\mathbf{t} = \begin{pmatrix} e \\ f \end{pmatrix}\) moves every point \(P(x, y)\) to \(P'(x', y')\) according to:$$\begin{pmatrix} x' \\
y' \end{pmatrix} = \begin{pmatrix} x \\
y \end{pmatrix} + \begin{pmatrix} e \\
f \end{pmatrix} = \begin{pmatrix} x+e \\
y+f \end{pmatrix}.$$
This is not a linear transformation (unless \(\mathbf{t}=\mathbf{0}\)) because the origin \((0,0)\) is mapped to \((e, f)\), not itself.
Example
Find the image of the position vector \(\begin{pmatrix} 2 \\ 3 \end{pmatrix}\) under translation by vector \(\begin{pmatrix} 1 \\ -2 \end{pmatrix}\).
$$\begin{aligned}\mathbf{x}' &= \mathbf{x} + \mathbf{t} \\
&= \begin{pmatrix} 2 \\
3 \end{pmatrix} + \begin{pmatrix} 1 \\
-2 \end{pmatrix} \\
&= \begin{pmatrix} 2+1 \\
3+(-2) \end{pmatrix} \\
&= \begin{pmatrix} 3 \\
1 \end{pmatrix}\end{aligned}$$ 
Skills to practice
- Applying Translations
II.2
Affine Transformation
Definition — Affine Transformation
An affine transformation is a combination of a linear transformation followed by a translation. It is represented by the matrix equation:$$\mathbf{x}' = \mathbf{A}\mathbf{x} + \mathbf{b}$$ where \(\mathbf{x} = \begin{pmatrix} x \\ y \end{pmatrix}\), \(\mathbf{A}\) is a \(2\times 2\) matrix (representing rotation, scaling, shear, etc.), and \(\mathbf{b} = \begin{pmatrix} e \\ f \end{pmatrix}\) is the translation vector. Example
Find the image of the point \(P(1, 2)\) under an affine transformation consisting of a rotation of \(90^\circ\) anti-clockwise followed by a translation of \(\begin{pmatrix} 3 \\ -1 \end{pmatrix}\).
The rotation matrix is \(\mathbf{R}_{90^\circ} = \begin{pmatrix} 0 & -1 \\ 1 & 0 \end{pmatrix}\). The translation vector is \(\mathbf{b} = \begin{pmatrix} 3 \\ -1 \end{pmatrix}\).$$\begin{aligned}\mathbf{x}' &= \begin{pmatrix} 0 & -1 \\
1 & 0 \end{pmatrix}\begin{pmatrix} 1 \\
2 \end{pmatrix} + \begin{pmatrix} 3 \\
-1 \end{pmatrix}\\
&= \begin{pmatrix} -2 \\
1 \end{pmatrix} + \begin{pmatrix} 3 \\
-1 \end{pmatrix}\\
&= \begin{pmatrix} 1 \\
0 \end{pmatrix}\\
\end{aligned}$$ The image point is \((1, 0)\).
Skills to practice
- Applying an Affine Transformation
- Identifying Affine Transformations
III
Composition and Area
III.1
Composition of Transformations
Definition — Composite Transformation
A composite transformation is the result of applying more than one transformation to an object. Proposition — Composition and Order
If linear transformation \(T_1\) has matrix \(\mathbf{A}\) and linear transformation \(T_2\) has matrix \(\mathbf{B}\), then applying \(T_1\) then \(T_2\) is the transformation with matrix \(\mathbf{B}\mathbf{A}\): $$\mathbf{x}' = (\mathbf{B}\mathbf{A})\mathbf{x}.$$ Since matrix multiplication is not commutative, the order of the transformations matters in general. (For affine transformations \(\mathbf{x} \mapsto \mathbf{A_1}\mathbf{x} + \mathbf{b_1}\) then \(\mathbf{x} \mapsto \mathbf{A_2}\mathbf{x} + \mathbf{b_2}\), composing gives \(\mathbf{x}' = \mathbf{A_2}\mathbf{A_1}\mathbf{x} + \mathbf{A_2}\mathbf{b_1} + \mathbf{b_2}\).)
If transformation \(T_1\) has matrix \(\mathbf{A}\) and transformation \(T_2\) has matrix \(\mathbf{B}\), applying \(T_1\) then \(T_2\) corresponds to the matrix multiplication \(\mathbf{B}\mathbf{A}\).$$\begin{aligned} \mathbf{x}' &= T_2(T_1(\mathbf{x}))\\
&= \mathbf{B}(\mathbf{A}\mathbf{x})\\
& = (\mathbf{B}\mathbf{A})\mathbf{x}\end{aligned} $$
Example
- Find the single matrix that represents a reflection in the \(x\)-axis followed by a rotation of \(90^\circ\) anti-clockwise.
- Find the single matrix that represents a rotation of \(90^\circ\) anti-clockwise followed by a reflection in the \(x\)-axis.
- Compare the results.
Let \(\mathbf{M}_x = \begin{pmatrix} 1 & 0 \\ 0 & -1 \end{pmatrix}\) be the reflection and \(\mathbf{R}_{90} = \begin{pmatrix} 0 & -1 \\ 1 & 0 \end{pmatrix}\) be the rotation.
- The combined transformation of rotation applied after reflection is$$\begin{aligned}\mathbf{T}_1 &= \mathbf{R}_{90} \mathbf{M}_x \\ &=\begin{pmatrix} 0 & -1 \\ 1 & 0 \end{pmatrix} \begin{pmatrix} 1 & 0 \\ 0 & -1 \end{pmatrix}\\ &= \begin{pmatrix} 0(1)+(-1)(0) & 0(0)+(-1)(-1) \\ 1(1)+0(0) & 1(0)+0(-1) \end{pmatrix}\\ &= \begin{pmatrix} 0 & 1 \\ 1 & 0 \end{pmatrix}\\ \end{aligned}$$ This represents a reflection in the line \(y=x\).
- The combined transformation of reflection applied after rotation is$$\begin{aligned}\mathbf{T}_2 &= \mathbf{M}_x \mathbf{R}_{90} \\ &=\begin{pmatrix} 1 & 0 \\ 0 & -1 \end{pmatrix} \begin{pmatrix} 0 & -1 \\ 1 & 0 \end{pmatrix}\\ &= \begin{pmatrix} 1(0)+0(1) & 1(-1)+0(0) \\ 0(0)+(-1)(1) & 0(-1)+(-1)(0) \end{pmatrix}\\ &= \begin{pmatrix} 0 & -1 \\ -1 & 0 \end{pmatrix}\\ \end{aligned}$$ This represents a reflection in the line \(y=-x\).
- We see that \(\mathbf{T}_1 \neq \mathbf{T}_2\). Therefore, the order of transformations matters.
Skills to practice
- Finding the Composite Matrix Representation
- Calculating and Identifying Composite Transformations
III.2
Area and Determinant
Proposition — Area Scaling Factor
Let \(\mathbf{A} = \begin{pmatrix} a & b \\ c & d \end{pmatrix}\) be the matrix of a linear transformation.If a shape \(F\) with area \(S\) is transformed by \(\mathbf{A}\), the area of the image shape \(F'\) is given by:$$ \text{Area}(F') = |\det(\mathbf{A})| \times S = |ad-bc| \times S $$ The absolute value of the determinant represents the area scale factor.
If \(\det(\mathbf{A}) = 1\) or \(-1\), the transformation preserves area (e.g., rotation, reflection).
If \(\det(\mathbf{A}) = 0\), the transformation maps the entire plane onto a line or a point (the area collapses to zero).
If \(\det(\mathbf{A}) = 0\), the transformation maps the entire plane onto a line or a point (the area collapses to zero).
Example
A unit square (Area = 1) is transformed by \(\mathbf{A} = \begin{pmatrix} 3 & 1 \\ 0 & 2 \end{pmatrix}\). Calculate the area of the image.
$$ \det(\mathbf{A}) = (3)(2) - (1)(0) = 6. $$ The area of the image is \(|6| \times 1 = 6\). 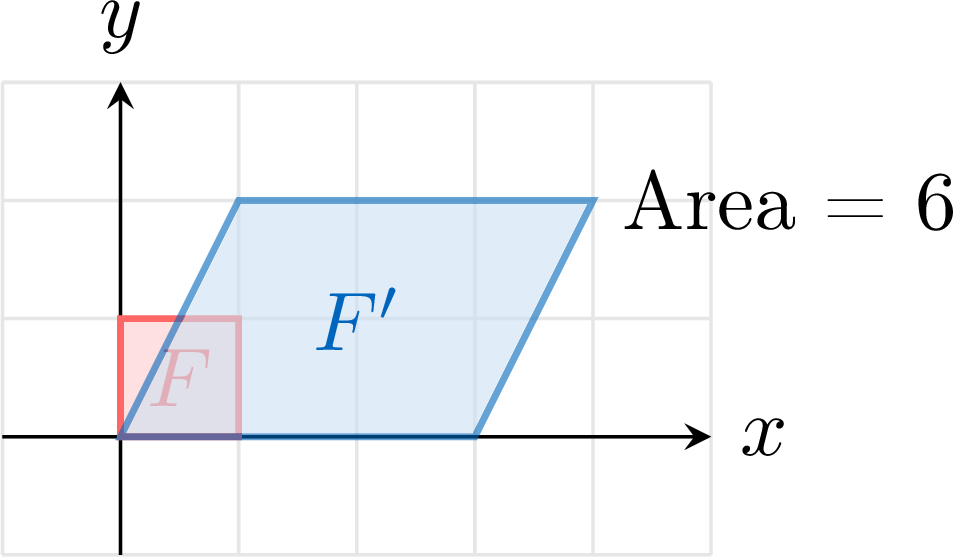
Area and Orientation Under an Affine Transformation
The translation part of \(\mathbf{x}' = \mathbf{A}\mathbf{x} + \mathbf{b}\) moves a shape without changing its area, so for an affine transformation too: $$\text{Area of the image} = |\det(\mathbf{A})| \times \text{Area of the object}.$$ The sign of \(\det(\mathbf{A})\) tells the orientation: if \(\det(\mathbf{A}) > 0\), the vertices of the image are met in the same direction of turning as those of the object (orientation kept, as for a rotation); if \(\det(\mathbf{A}) < 0\), the direction is reversed (orientation reversed, as for a reflection). If \(\det(\mathbf{A}) = 0\), the image is flattened onto a line or a point: its area is \(0\), and it has no orientation.
Example
The triangle with vertices \(O(0, 0)\), \(P(4, 0)\) and \(Q(0, 3)\) is transformed by $$\mathbf{x}' = \begin{pmatrix} 2 & 1 \\
1 & -1 \end{pmatrix}\mathbf{x} + \begin{pmatrix} 3 \\
-2 \end{pmatrix}.$$ Find the area of the image, and say whether the transformation keeps the orientation.
The triangle \(OPQ\) is right-angled at \(O\): its area is \(\frac{1}{2} \times 4 \times 3 = 6\). With \(\mathbf{A} = \begin{pmatrix} 2 & 1 \\ 1 & -1 \end{pmatrix}\): $$\begin{aligned}[t] \det(\mathbf{A}) &= (2)(-1) - (1)(1) \\
&= -3. \end{aligned}$$ $$\begin{aligned}[t] \text{Area of the image} &= |\det(\mathbf{A})| \times \text{Area of the object} && \text{(area under an affine transformation)} \\
&= 3 \times 6 \\
&= 18. \end{aligned}$$ Since \(\det(\mathbf{A}) < 0\), the orientation is reversed. The images of the vertices are \(O'(3, -2)\), \(P'(11, 2)\) and \(Q'(6, -5)\): \(O \to P \to Q\) turns anti-clockwise, while \(O' \to P' \to Q'\) turns clockwise. 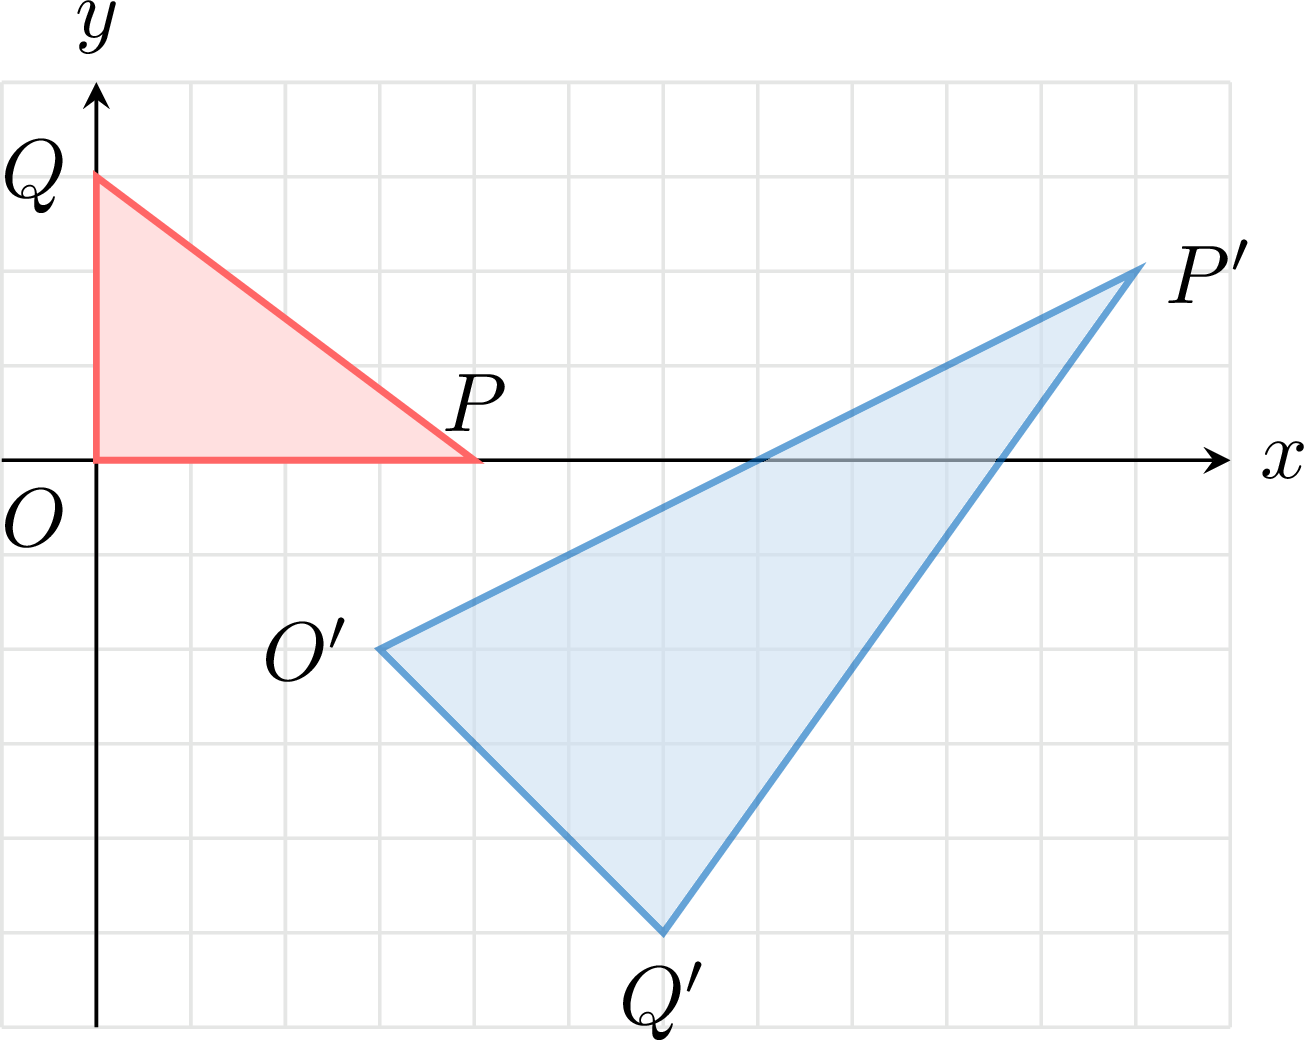
Skills to practice
- Finding the Area of the Image
- Finding Unknowns Using Area
IV
Going further
Skills to practice
- Reasoning with Transformations
- Solving Problems
- Quiz
Jump to section